ZephastraZEPHASTRAROBOTICS
PROJECT 03 · SIMULATION CASE STUDY

Mobile Manipulator: Visual Pick, Transport & Return Alignment

An independent ROS 2 and Gazebo experiment connects navigation, color-marker perception, SCARA manipulation, tray transport, and camera-based return alignment.

ROS 2GazeboNav2OpenCVSCARA
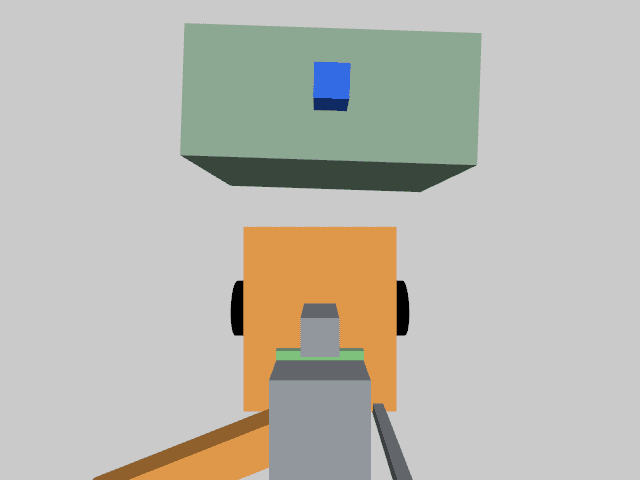
Actual camera evidence from the repository: the blue material, pickup table, and robot—not a concept render.
Actual camera evidence from the repository: the blue material, pickup table, and robot—not a concept render. Original evidence

What this experiment validates

  • Navigate with Nav2 / AMCL and detect blue material and a red placement marker using camera images.
  • Use a four-degree-of-freedom SCARA arm for bounded pick-and-place, tray loading, transport, and unloading.
  • Follow coarse return navigation with camera-based rectangular-marker alignment; record stage reports and test cancellation stopping with cargo retained.

Validation boundaries

  • Grasping and tray retention use explicit rigid-body constraints—not contact-friction grasping.
  • Color markers, known table height, and constrained arm motions target the designed scene—not general-purpose perception or full-scene MoveIt planning.
  • Local, single-item, single-mission simulation only; no hardware acceptance, long-run success-rate study, or industrial safety certification.

Environment and reproduction

Locally verified on WSL Ubuntu, ROS 2 Lyrical, Gazebo Sim 10.4, and /opt/nav2. System dependencies must already be installed; clean-system installation and cross-machine reproduction are not fully verified.

These commands assume the system dependencies listed in the README are already installed. doctor.sh checks dependencies; it does not install them. The first run builds plugins. Do not send manual Nav2 goals during the automated mission.

git clone https://github.com/zephastra/robotics.git
cd robotics
git checkout 8f2fbe53f616c905262efc589711b65510b1bdbd
cd projects/03-mobile-manipulator
bash scripts/doctor.sh
bash scripts/test.sh
bash run_demo.sh

Commands are pinned to the reviewed revision. See the upstream README for full prerequisites and subsequent updates.

Evidence and source

Published validation includes GUI and headless mission reports, camera evidence, cancellation-stop tests, and unit tests. COMPLETED requires successful pickup, loading, transport, placement, and return checks.
Source revision: 8f2fbe53f616c905262efc589711b65510b1bdbd