ZephastraZEPHASTRAROBOTICS
PROJECT 04 · SIMULATION CASE STUDY

MuJoCo Humanoid Locomotion & Task Validation

Experiments with upstream pretrained Unitree G1 and EngineAI T800 gait policies focus on waypoint tasks, position holding, manual control, cancellation, and disturbance evidence.

MuJoCoUnitree G1EngineAI T800Pretrained Policies
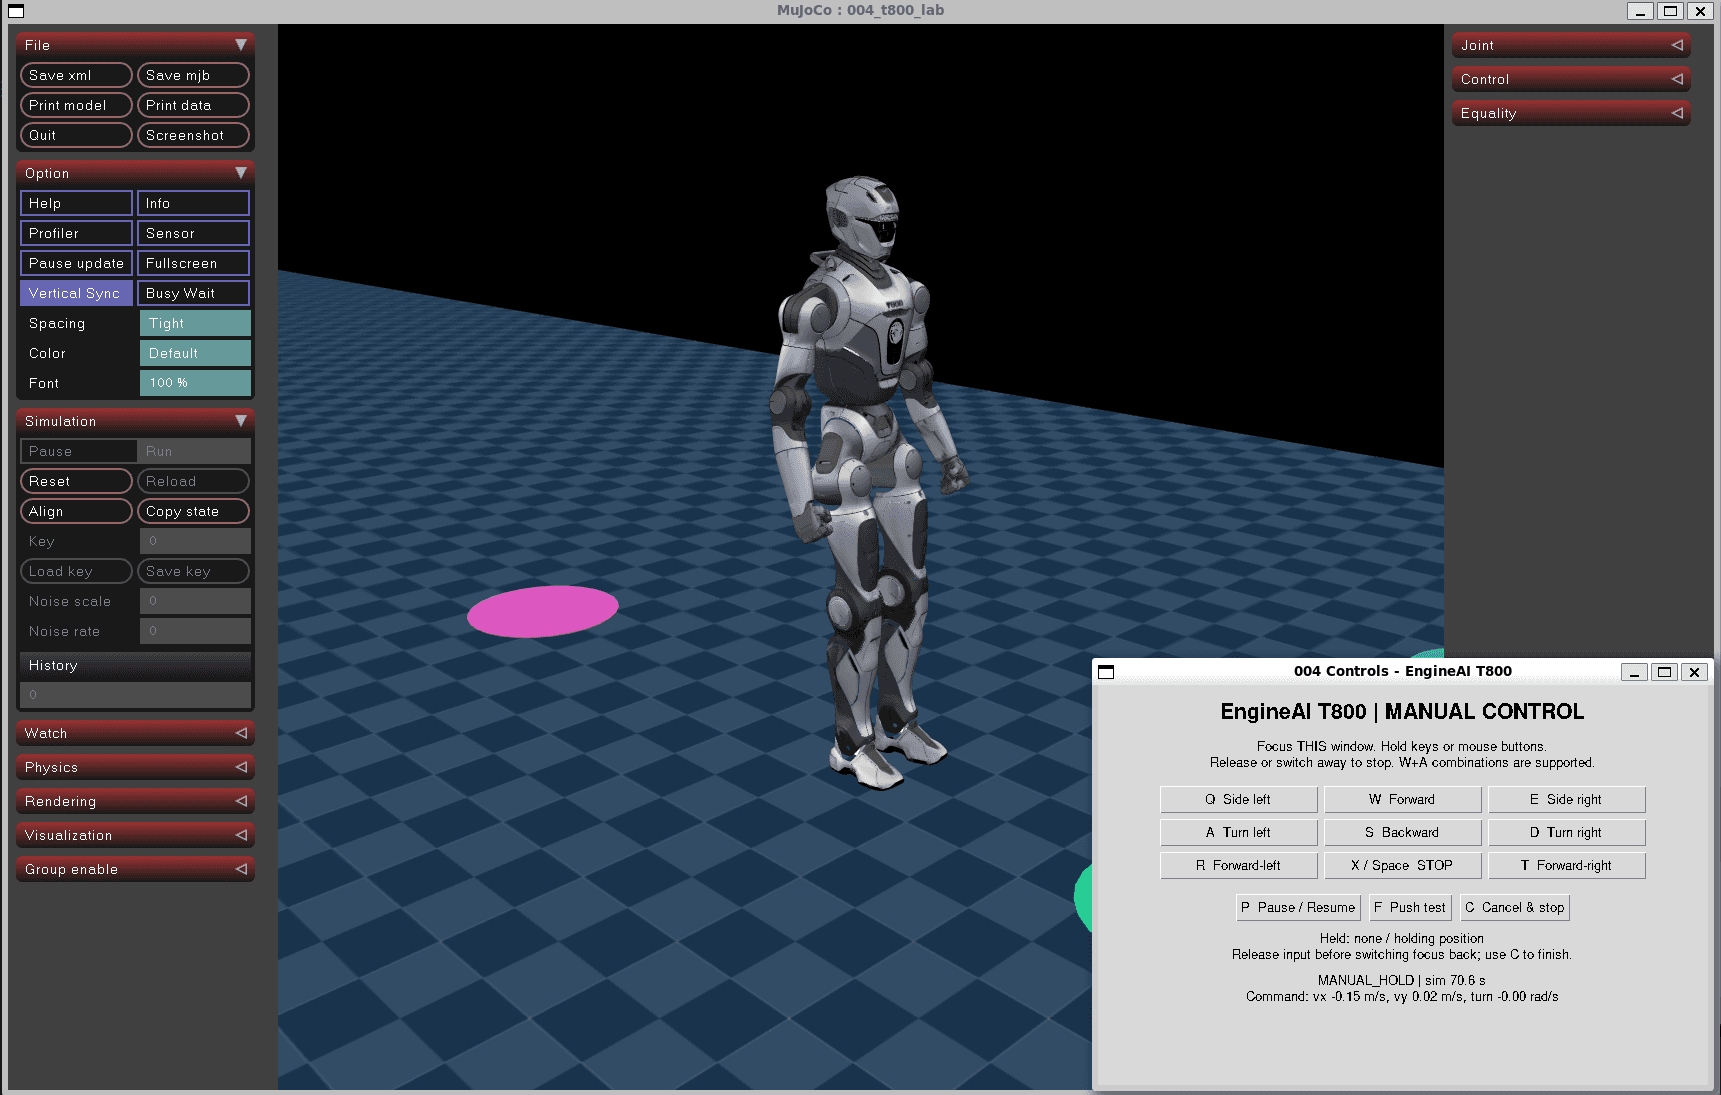
Actual T800 manual-control screenshot from the repository: the MuJoCo scene and companion control window.
Actual T800 manual-control screenshot from the repository: the MuJoCo scene and companion control window. Original evidence

What this experiment validates

  • Reuse upstream pretrained gait policies and add waypoint tasks, feedback control, and reporting; upstream policy training is not claimed as original work.
  • Run G1 / T800 route, hold, cancellation, push, and fall-detection experiments with JSON / CSV reports and plots.
  • Reset manual velocity commands on key release or focus loss; continue balance control after a task stop.

Validation boundaries

  • The task layer uses MuJoCo ground-truth position feedback—not SLAM, real perception-based navigation, or obstacle avoidance.
  • Bounded flat-ground simulation only: no hardware, stairs, jumping, stand-up recovery, or manipulation validation.
  • A stop command is not motor power-off. The heartbeat is not an independent safety guarantee when the main thread blocks.

Environment and reproduction

README baseline: Ubuntu 26.04 / WSLg, Python 3.12.13, MuJoCo 3.3.6, and PyTorch 2.7.1 CPU; T800 also requires MNN 3.6.1. Independent of ROS and Gazebo.

Requires git, uv, and a compatible environment. setup.sh installs dependencies and retrieves upstream assets. For T800, also run bash scripts/setup_t800.sh and bash scripts/doctor.sh --robot t800, then bash run_demo.sh --robot t800 --mode manual.

git clone https://github.com/zephastra/robotics.git
cd robotics
git checkout 8f2fbe53f616c905262efc589711b65510b1bdbd
cd projects/04-humanoid-locomotion
bash scripts/setup.sh
bash scripts/doctor.sh
bash run_demo.sh --robot g1

Commands are pinned to the reviewed revision. See the upstream README for full prerequisites and subsequent updates.

Evidence and source

The public README and validation record document conditions, results, and limits for route, hold, cancellation, and disturbance experiments. Earlier validation and later manual-control checks have different dates; they are not merged into universal reliability claims.
Source revision: 8f2fbe53f616c905262efc589711b65510b1bdbd