ZephastraZEPHASTRAROBOTICS
PROJECT 01 · SIMULATION CASE STUDY

ROS 2 AMR Mapping, Localization & Nav2 Navigation

A Gazebo differential-drive robot connects lidar, odometry, TF, online SLAM, AMCL, and Nav2 into an end-to-end mapping-to-navigation workflow.

ROS 2GazeboSLAM ToolboxAMCLNav2
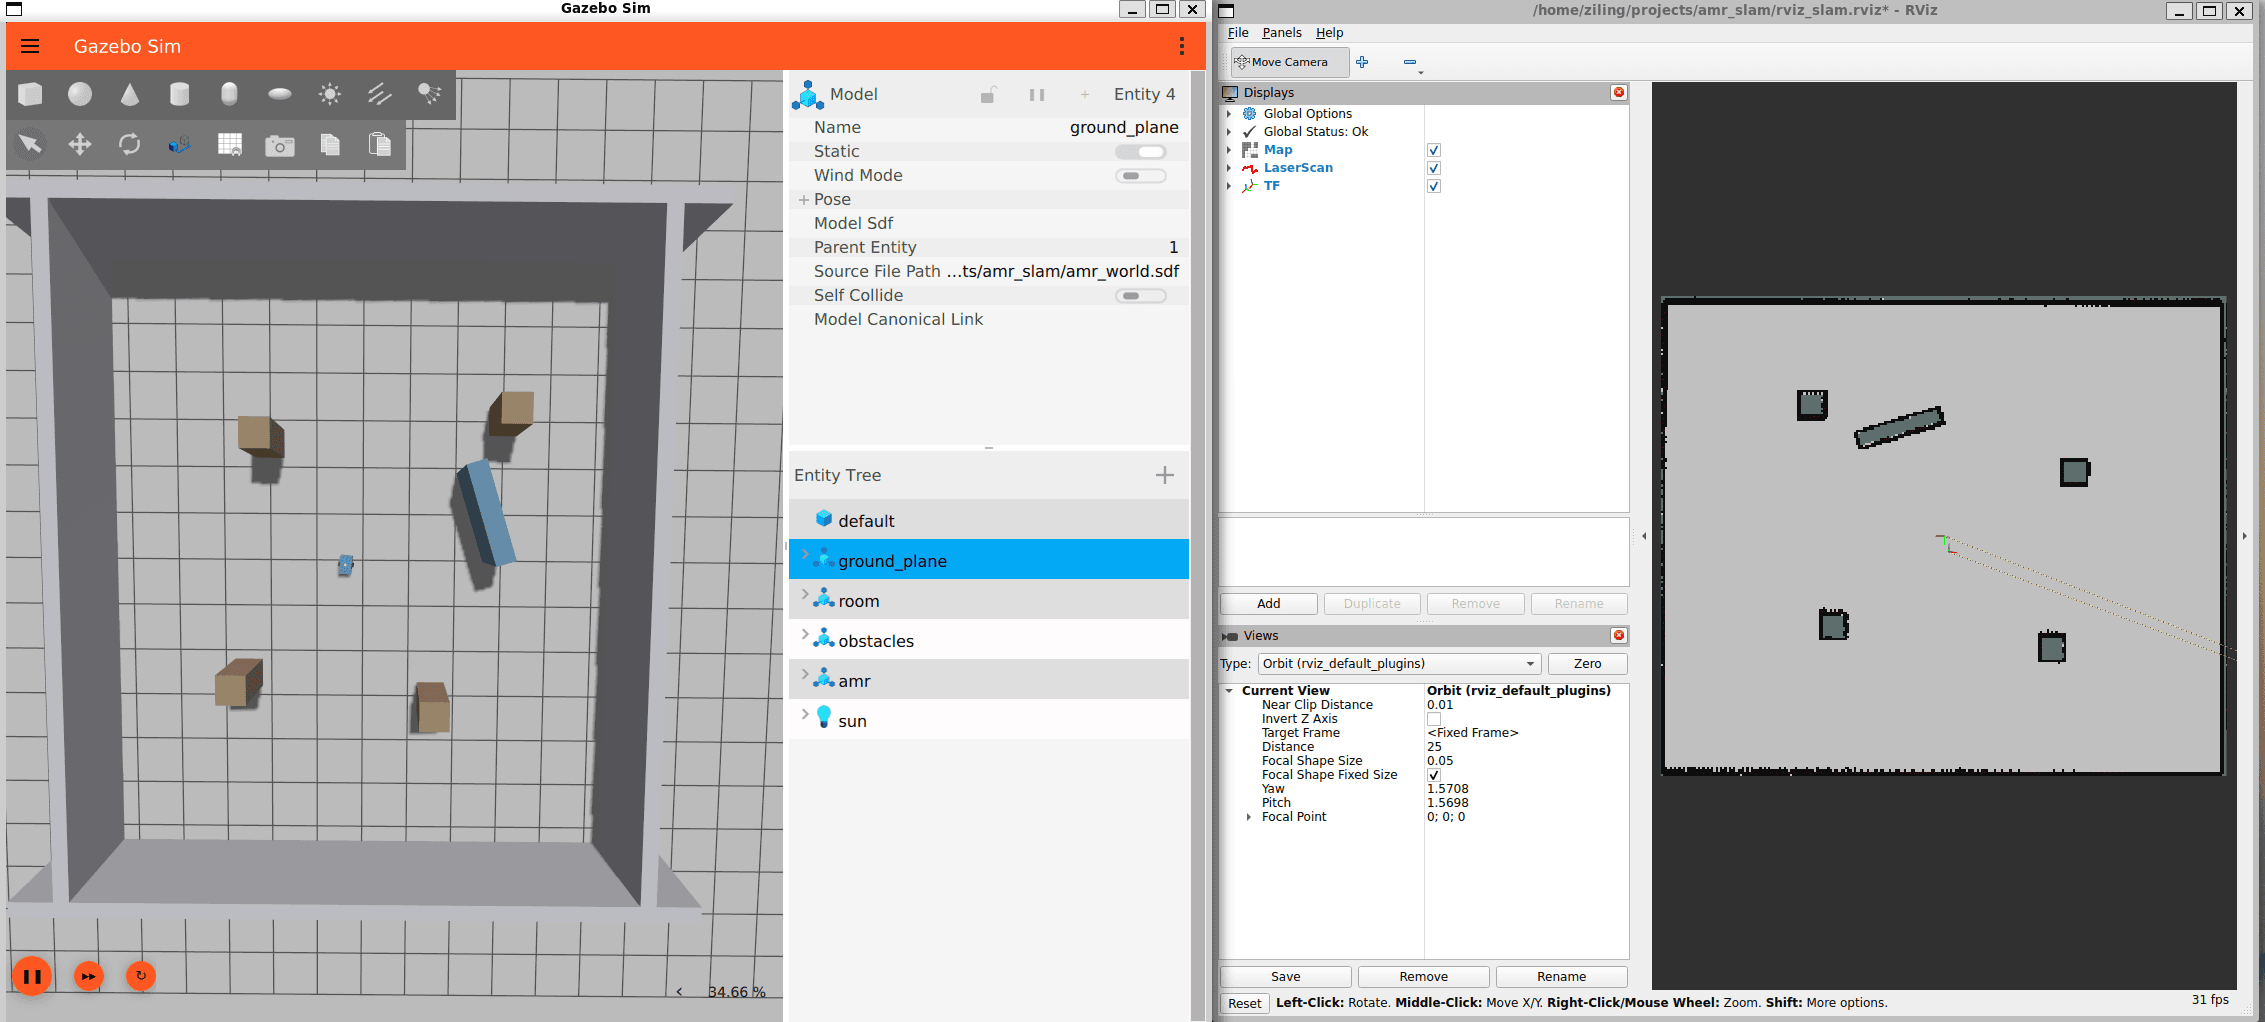
Actual repository screenshot: Gazebo simulation on the left; lidar and the 2D map in RViz on the right.
Actual repository screenshot: Gazebo simulation on the left; lidar and the 2D map in RViz on the right. Original evidence

What this experiment validates

  • Bridge /scan and /odom into ROS 2 and establish map → odom → base_link → laser_link.
  • Build a map with asynchronous SLAM Toolbox and save map.pgm and map.yaml.
  • Localize with AMCL, send Nav2 goals, and inspect topics, TF, lifecycle nodes, and actions with check_nav2.sh.

Validation boundaries

  • An introductory simulation—not validated hardware safety settings or field navigation reliability.
  • Wheel odometry does not fuse an IMU. Slip, collisions, and prolonged wall contact can still produce map drift.

Environment and reproduction

Verified baseline: Ubuntu 26.04 / WSL 2, ROS 2 Lyrical, Gazebo ROS vendor 10.4.0, Cyclone DDS, and RViz 2 / WSLg. The test machine also has Jetty nightly packages; other versions have not been validated end to end.

Install ROS 2 Lyrical and configure its package repositories first. While mapping runs, use another terminal to execute bash scripts/save_map.sh. Exit mapping before running bash scripts/run_nav2.sh; SLAM and AMCL must not run together.

git clone https://github.com/zephastra/robotics.git
cd robotics
git checkout 8f2fbe53f616c905262efc589711b65510b1bdbd
cd projects/01-amr-slam
bash scripts/install.sh
bash scripts/run_mapping.sh

Commands are pinned to the reviewed revision. See the upstream README for full prerequisites and subsequent updates.

Evidence and source

The README records end-to-end mapping, map saving, localization, and goal navigation validation for v0.2.0. The Nav2 document provides operating steps and acceptance criteria—not a cross-hardware success-rate study.
Source revision: 8f2fbe53f616c905262efc589711b65510b1bdbd